Trajectopy - Trajectory Evaluation in Python


Trajectopy is a Python package with an optional graphical user interface for empirical trajectory evaluation.
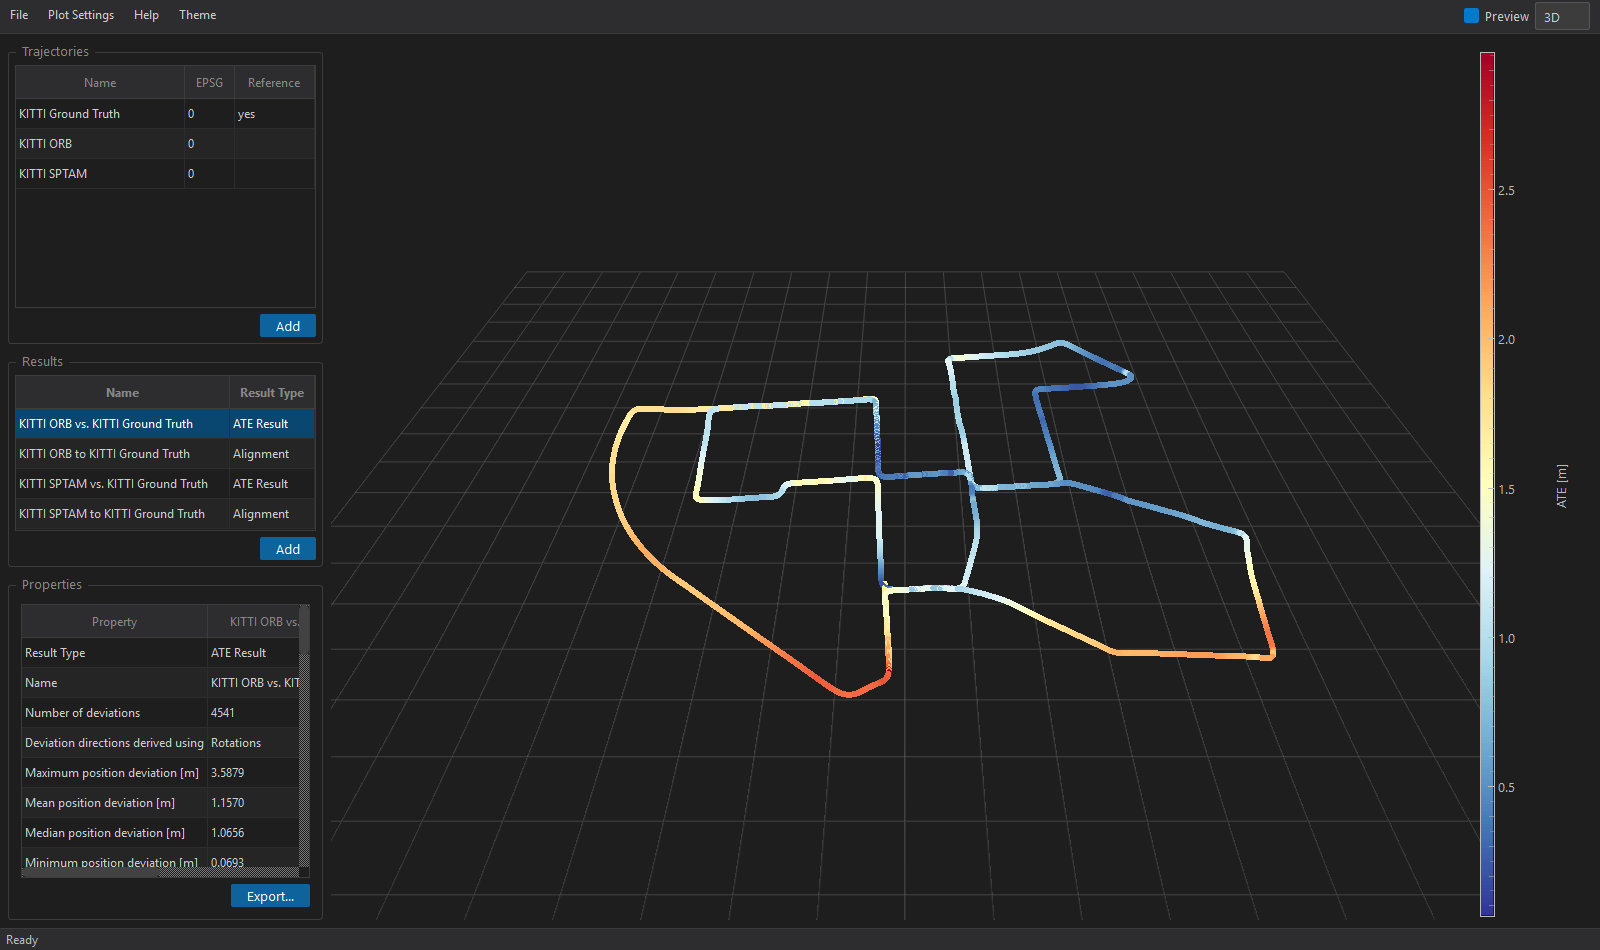
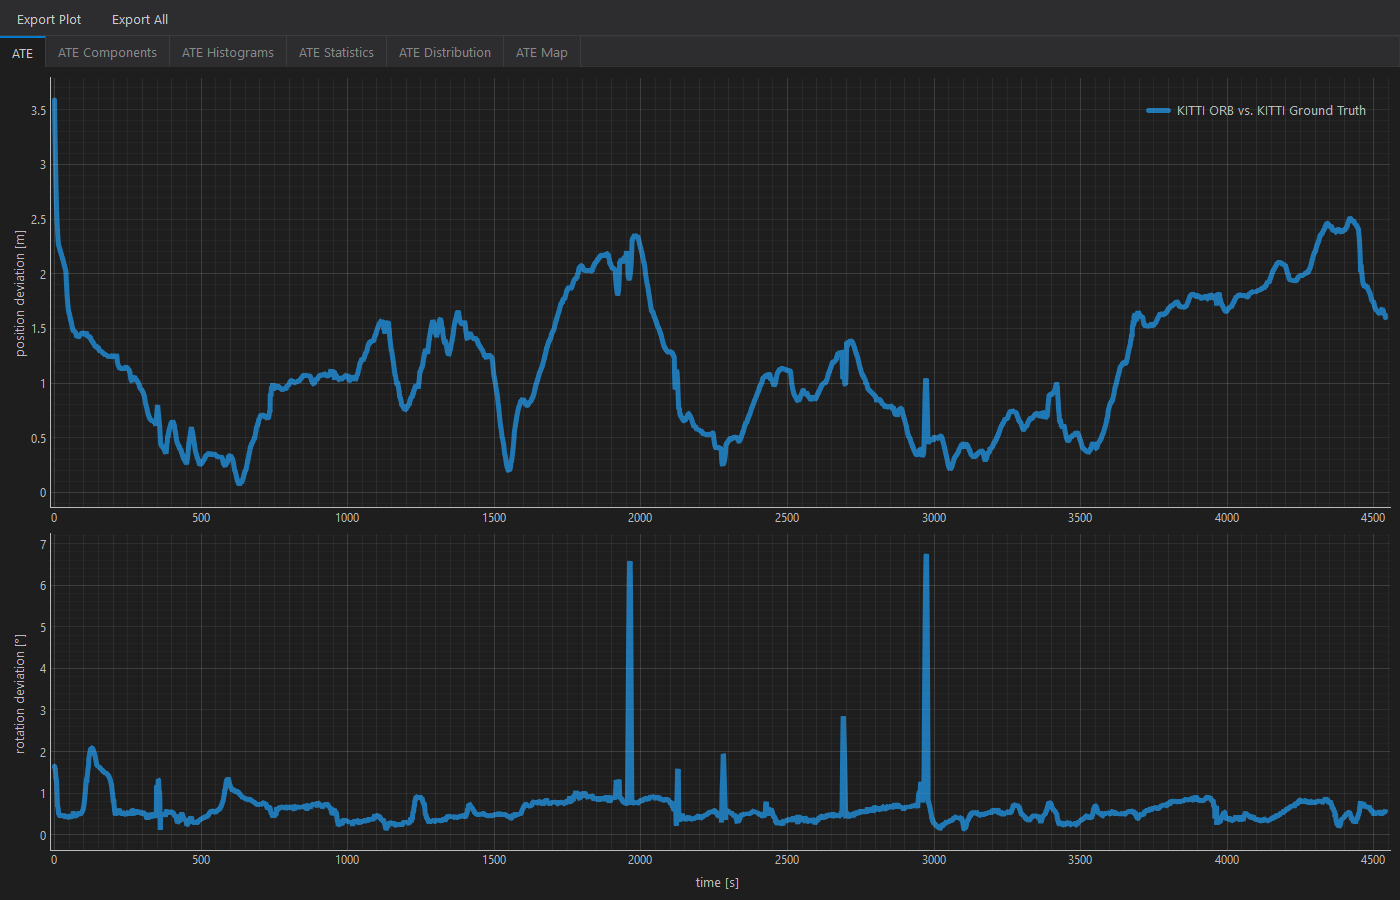
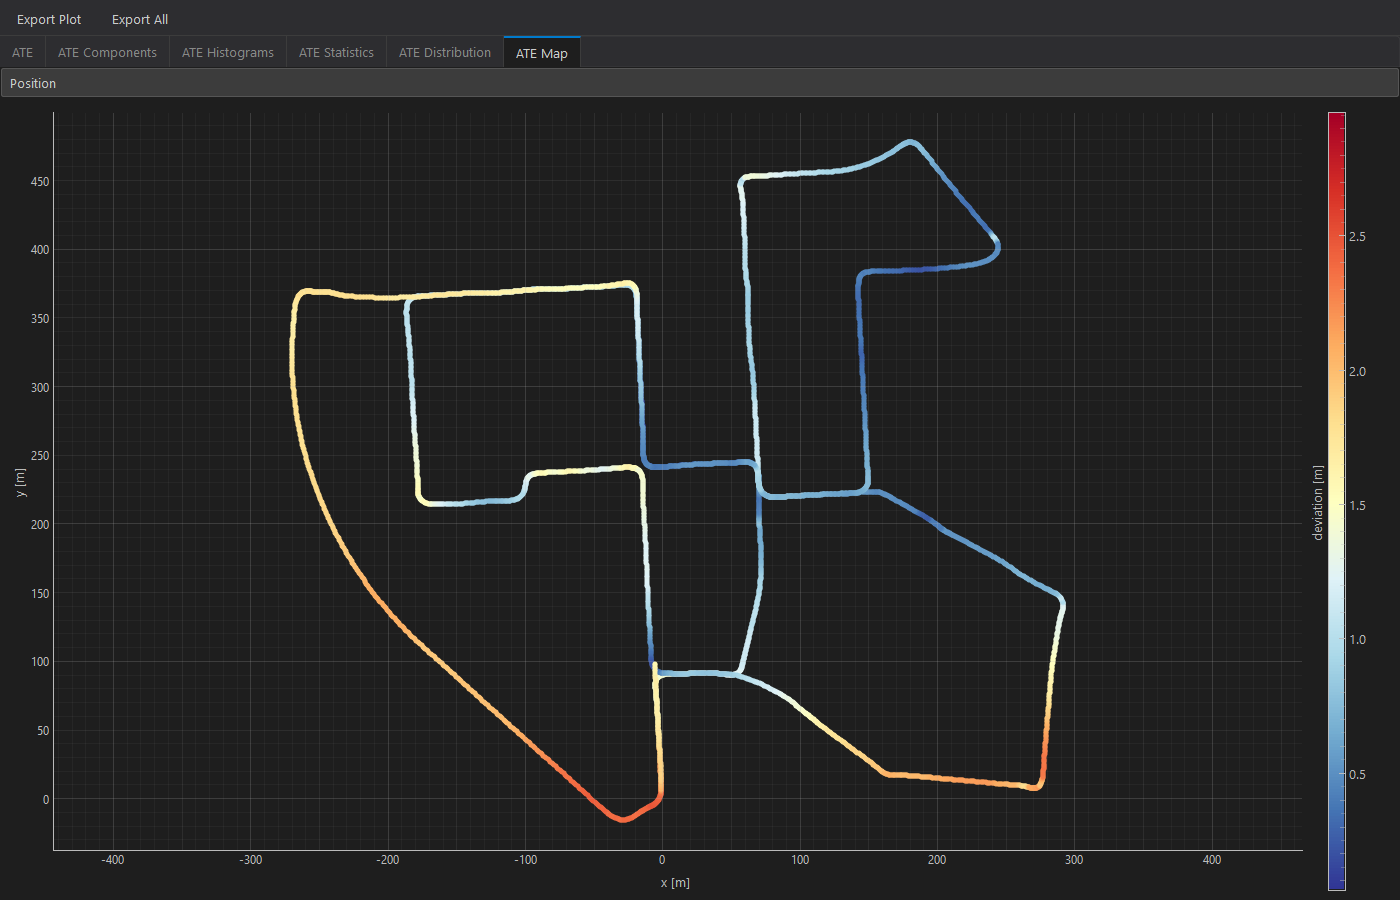
Key Features
- Interactive GUI: Load, plot, align and compare trajectories without writing code. Every action explains itself in the context menus, and trajectories can be aligned interactively if an automatic alignment is not possible.
- Alignment: A spatio-temporal least squares alignment that can be tailored to the application: similarity transformation, leverarm and time shift, each of them optional.
- Comparison: Absolute and relative trajectory error (ATE and RPE), computed with various pose-matching methods.
- Data Import/Export: ASCII files with configurable columns, time formats and coordinate systems (any EPSG code), and ROS bags.
- Fast, Interactive Visualization: Powered by pyqtgraph, the same plots are available in the GUI and in Python scripts, stay fluid for large trajectories, and can be exported to PNG, JPG or SVG. Georeferenced trajectories and ATE results can be exported to Google Earth, colored by speed, height or deviations, on the terrain or at their own heights, with playback.
Installation
Windows App
Download Trajectopy-<version>-setup.exe from the latest release
and run it. No Python installation or administrator rights are needed. The installer adds Trajectopy to the Start
menu and, optionally, opens .traj files with it on double-click. The app reports new versions (Help → Check for
Updates); installing a newer version over an existing one updates it.
As the installer is not signed, Windows SmartScreen may warn about an unknown publisher: choose More info → Run anyway.
Python Package
| Command | Contents |
|---|---|
pip install "trajectopy[gui]" |
Python package and GUI (recommended) |
pip install "trajectopy[plot]" |
Python package with plotting, without the GUI |
pip install trajectopy |
Python package only |
Trajectopy requires Python 3.10 or newer.
Faster loading of large files: trajectory files with millions of poses load several times faster with the
optional fast extra, which installs pyarrow for reading. It can be
combined with the other extras:
Quick Start
Python
Load two trajectories and compute the absolute and relative trajectory error. The example files are in the
example_data folder of the repository.
import trajectopy as tpy

reference = tpy.Trajectory.from_file("./example_data/KITTI_gt.traj")
estimate = tpy.Trajectory.from_file("./example_data/KITTI_ORB.traj")

# ATE: the estimate is aligned to the reference first (similarity transformation)
ate_result = tpy.ate(trajectory=estimate, other=reference)
print(f"Position ATE: {ate_result.pos_ate:.3f} m")

# RPE: drift per 100 m to 800 m (see the relative comparison settings)
rpe_result = tpy.rpe(trajectory=estimate, other=reference)
print(f"Position RPE: {rpe_result.pos_rpe:.3f} {rpe_result.pos_drift_unit}")
The User Guide covers alignment, evaluation, plots and the GUI in detail.
GUI
Start the Windows app from the Start menu, or run:
Drop trajectory files onto the trajectory table, right-click the ground truth and choose Set as Reference, then right-click another trajectory and choose Compare with Reference. See Using the GUI.
Command Line
| Argument | Description |
|---|---|
files |
Project (.tpy), trajectory (.traj, .bag) or result (.result) files to open at start. Trajectories and results are added to the project. |
--version, -v |
Show the version and exit. |
--single-thread |
Process in the GUI thread instead of a background thread, e.g. for debugging. The GUI does not respond while processing. |
--plot-settings PLOT_SETTINGS |
JSON file with plot settings; settings missing in the file keep their default values. |
-h, --help |
Show the help and exit. |
Examples:
trajectopy ground_truth.traj slam.traj
trajectopy flight.tpy
trajectopy --plot-settings plot_settings.json
A project contains its own plot settings, which replace those given with --plot-settings when it is opened.
The Windows app has no console window, so --version and --help print nothing there; the version is shown in
Help → About. Messages of the running GUI are shown in its log (View → Log).
Citation
If you use Trajectopy for academic work, please cite our paper:
@article{Tombrink2024,
  title = {Spatio-temporal trajectory alignment for trajectory evaluation},
  author = {Gereon Tombrink and Ansgar Dreier and Lasse Klingbeil and Heiner Kuhlmann},
  journal = {Journal of Applied Geodesy},
  year = {2024},
  doi = {10.1515/jag-2024-0040},
  url = {https://doi.org/10.1515/jag-2024-0040},
  codeurl = {https://github.com/gereon-t/trajectopy}
}
License
Trajectopy is released under the GNU General Public License v3.0.
Contributing
Contributions are welcome! Please see our GitHub repository for details.
Developed at the Institute of Geodesy and Geoinformation, University of Bonn